Common questions about Wolfrom (3K) planetary gearboxes and how to use the calculator above.
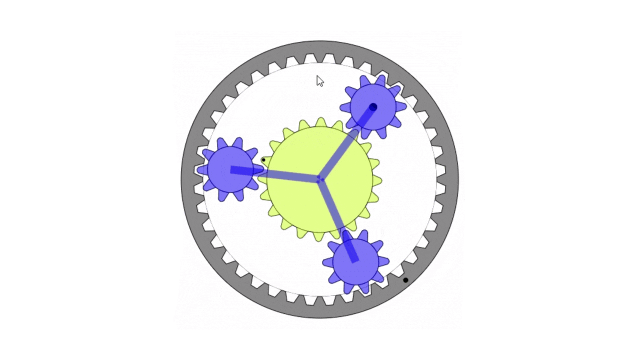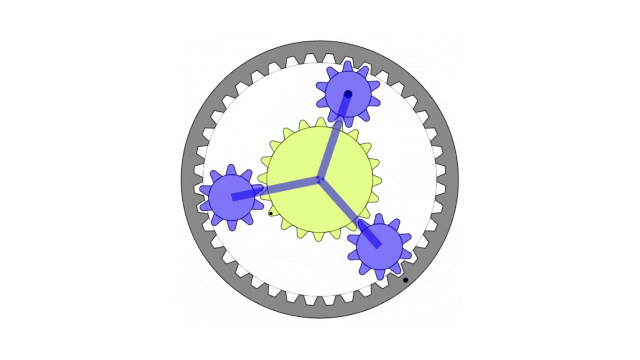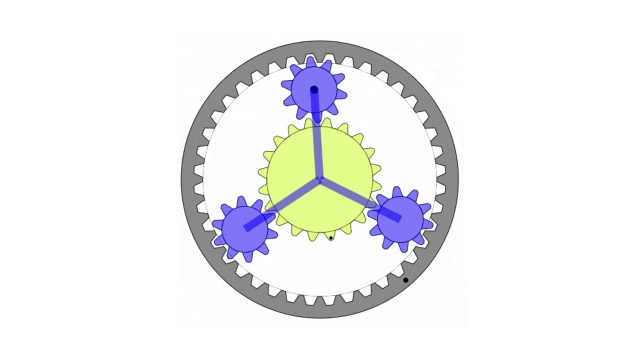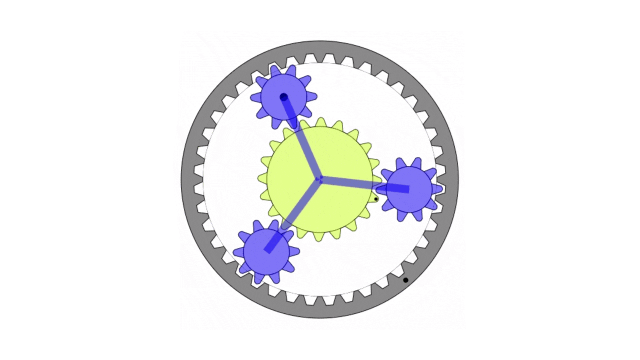
A Wolfrom drive is a compound planetary gearbox, also called a 3K planetary drive or split-ring planetary. It has a sun gear, planets that carry two gears on one shaft (Planet 1 and Planet 2), a fixed ring gear and an output ring gear. The two ring gears have slightly different tooth counts. As the planets orbit, that small difference makes the output ring turn very slowly, which gives a very high reduction ratio in one compact stage.
With the sun as input, the fixed ring held and the output ring as output, the reduction is:
Here Zs is the sun, Zp1 and Zp2 are the two planet gears, Zr1 is the fixed ring and Zr2 is the output ring. For example, with Zs = 14, Zp1 = 18, Zp2 = 17, Zr1 = 50 and Zr2 = 49, the ratio is 126:1. The calculator above does this for you and updates the 3D model live.
The ratio depends on how close the two stages' ring-to-planet ratios are. When they are nearly equal, the term in the formula's denominator gets very small, so the reduction becomes very large. A one-tooth change can move the ratio from tens to hundreds. If the second stage's ratio passes the first, the output turns the opposite way, and the calculator shows a negative ratio.
The trade-off is that efficiency usually drops as the ratio goes up, and very high-ratio designs are often hard or impossible to back-drive.
Two conditions limit the planet count. The planets must physically fit around the sun without their tooth tips colliding. And for equal spacing, (sun teeth + fixed ring teeth) must be divisible by the number of planets. The second stage adds a third condition: Planet 2 must also mesh with the output ring. In practice, the Planet 2 gear on each planet is often rotated (clocked) slightly differently. The calculator lists the planet counts that meet these conditions.
Both stages share the same carrier, so their center distances must match. With one module throughout, the output ring needs exactly sun + Planet 1 + Planet 2 teeth. A different module for Planet 2 and the output ring opens up other tooth combinations. The calculator adjusts module 2 slightly so the output ring has a whole number of teeth. Profile shifting is another common way to get the same freedom.
If both planet gears have the same pitch diameter, the fixed ring and output ring move in perfect step. The output never turns, which is an infinite reduction. The two gears must differ by at least one tooth, or have different pitch diameters with a different module.
Yes. "Download STEP" exports the full assembly as 3D solids in millimetres: the sun, every planet, the fixed ring and the output ring. It works in Fusion, SolidWorks, Onshape, FreeCAD and other CAD programs. The teeth are true involutes and the gears are positioned in mesh. The model has zero backlash and no root fillets, and the face width is 10 × module. Add backlash and fillets before manufacturing or 3D printing.
They are popular wherever high torque needs to fit in a small space: robot joints and actuators, exoskeletons, camera and antenna positioners, solar trackers, winches and 3D-printed hobby gearboxes. They are attractive because they use only standard spur gears and need no special manufacturing.

© Me Virtuoso All Rights Reserved 2026